Hi there! I am a tenure-track assistant professor at the Department of Computer Science, University of North Carolina at Chapel Hill (UNC), leading the Intelligent Dexterous Embodied AI Lab (IDEAL@UNC). I was a postdoc at BAIR@UC Berkeley and was a visiting PhD at CSAIL@MIT. I received my doctorate from the University of Hong Kong and finished my undergraduate degrees at Renmin University of China.
Research Highlights
I’m interested in building intelligent robots capable of interacting with the physical world as naturally and dexterously as humans. My research centers on dexterous manipulation, spanning any methods that can push the boundaries of robotic dexterity. Selected works are organized by research area. To learn more, please visit [Full Publication List] and [Lab Website].

Current as Touch

DexVerse

RSS26: OHRA

TMech26: DexH2R

CoorDex

ICRA25: Palletization
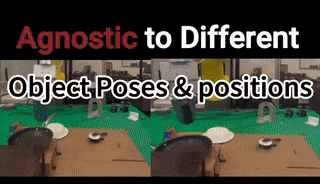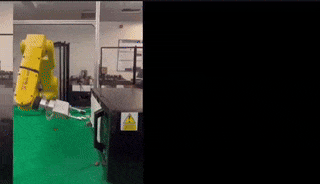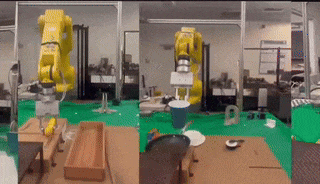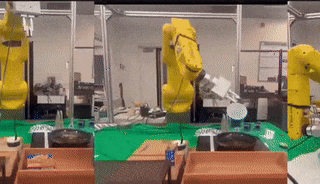
ICRA25: Manipulation via Scene Flow
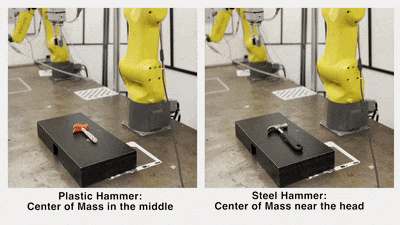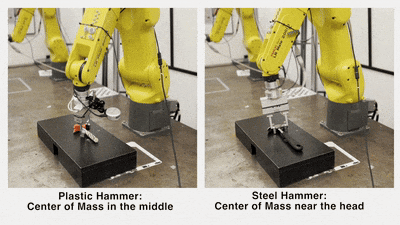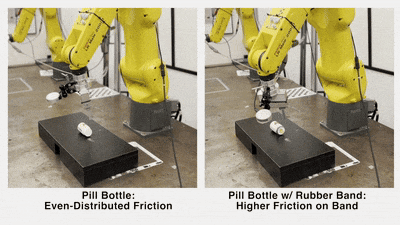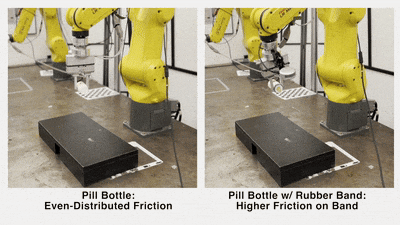
IROS25: PhyGrasp
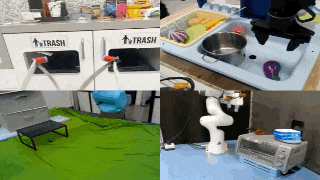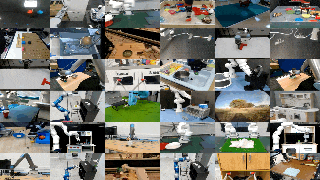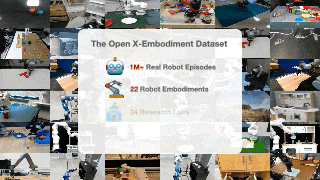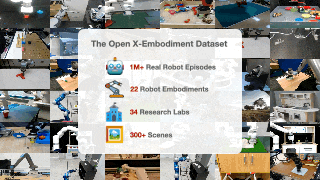
ICRA24: RT-X
NeurIPS23: EmbodiedGPT
CoRL24: Sparse Diffusion Policy
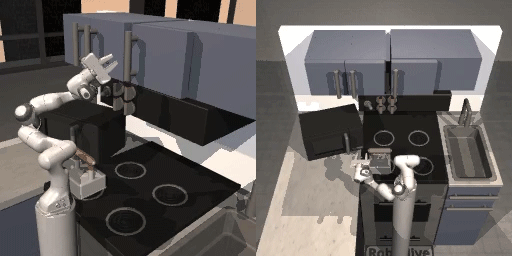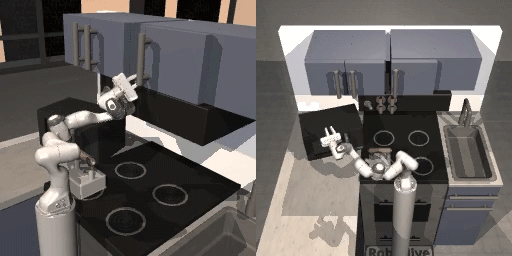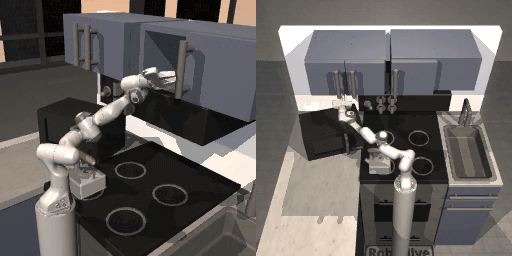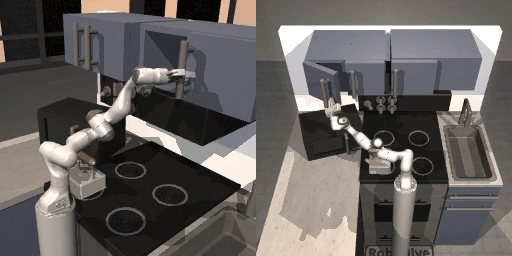
CVPR23: EC for Embodied Control
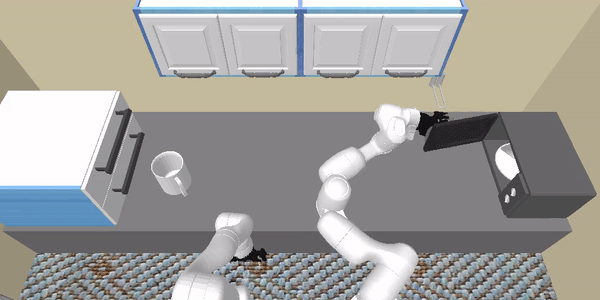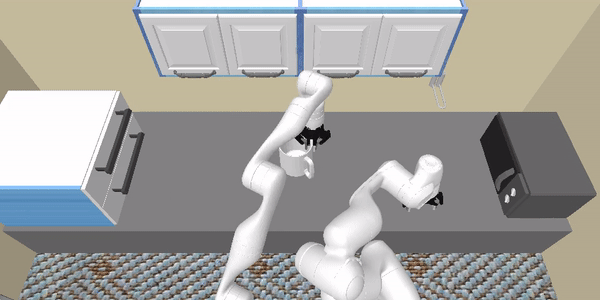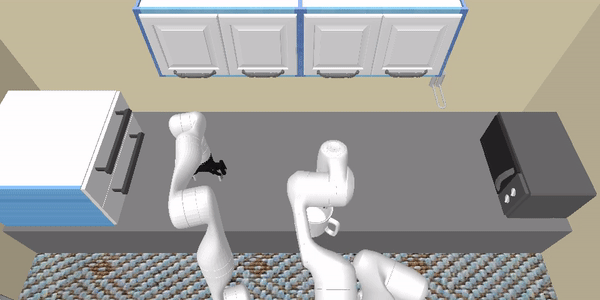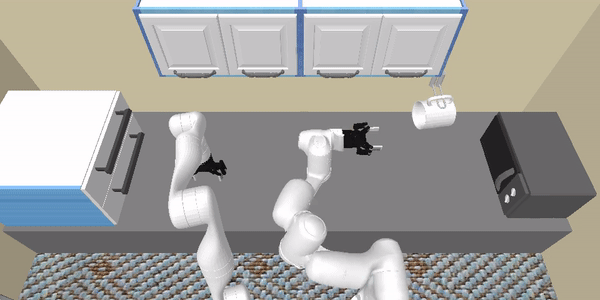
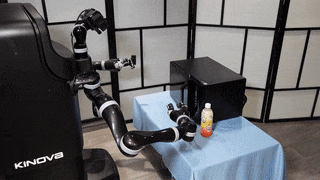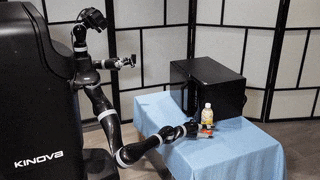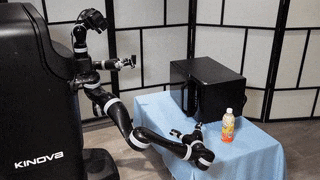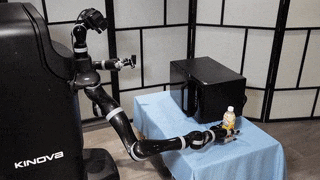
Preprint: Long-Horizon Tasks with LLM
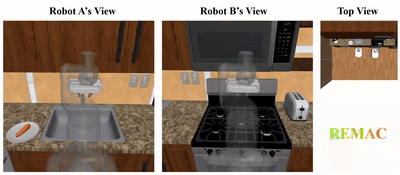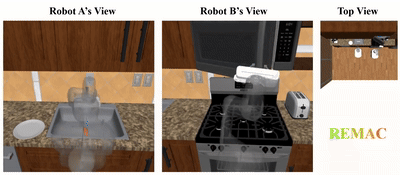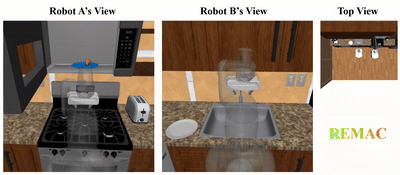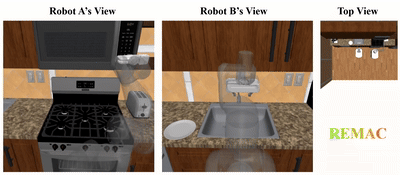
Preprint: REMAC
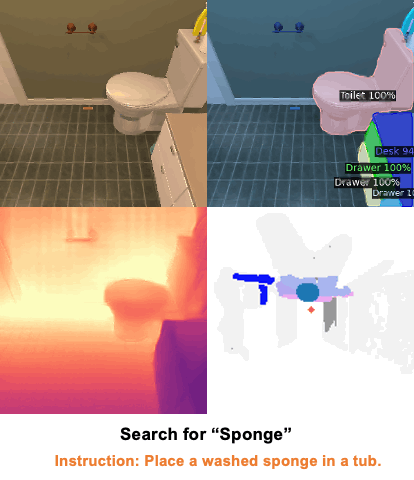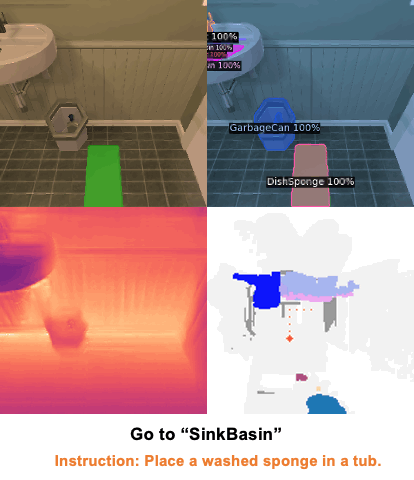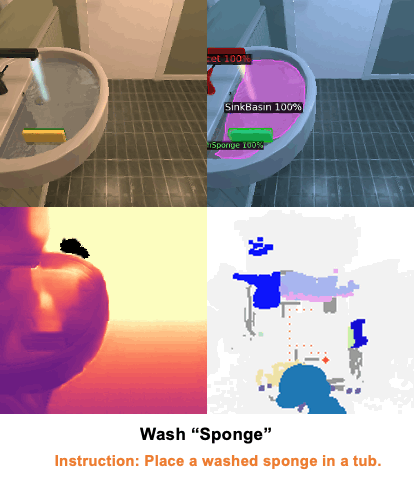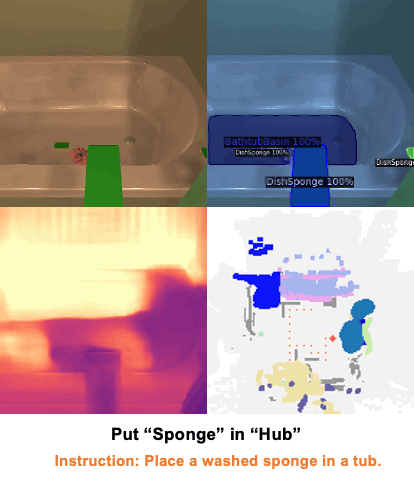
CoRL22: Embodied Concept Learner
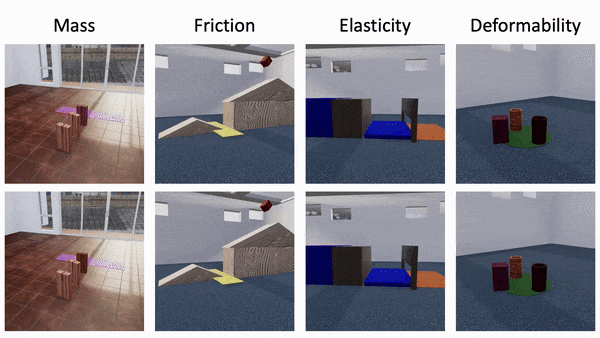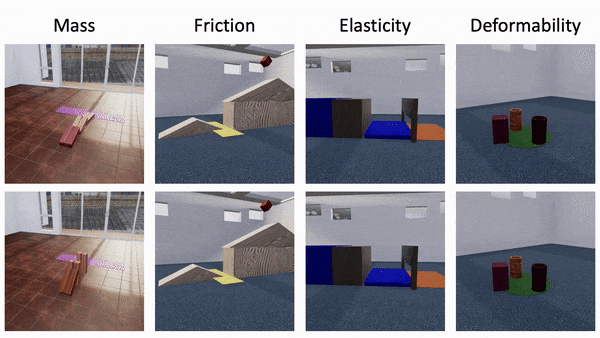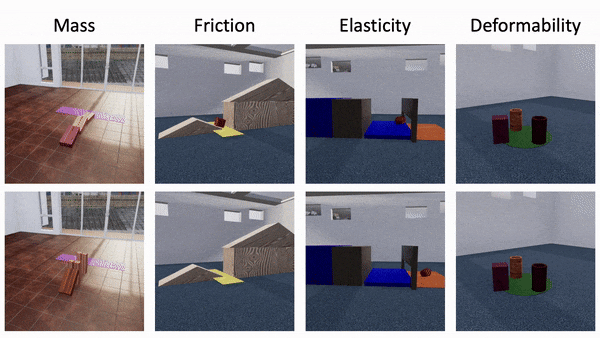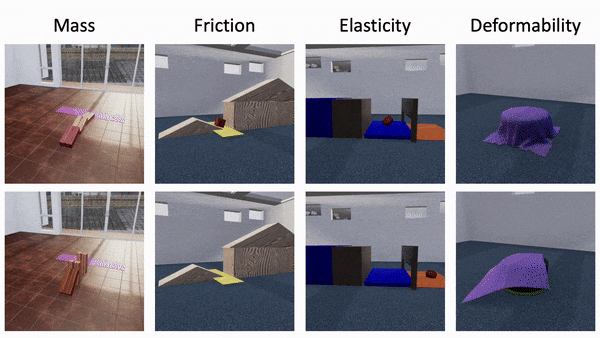
NeurIPS23 Dataset: Physion++
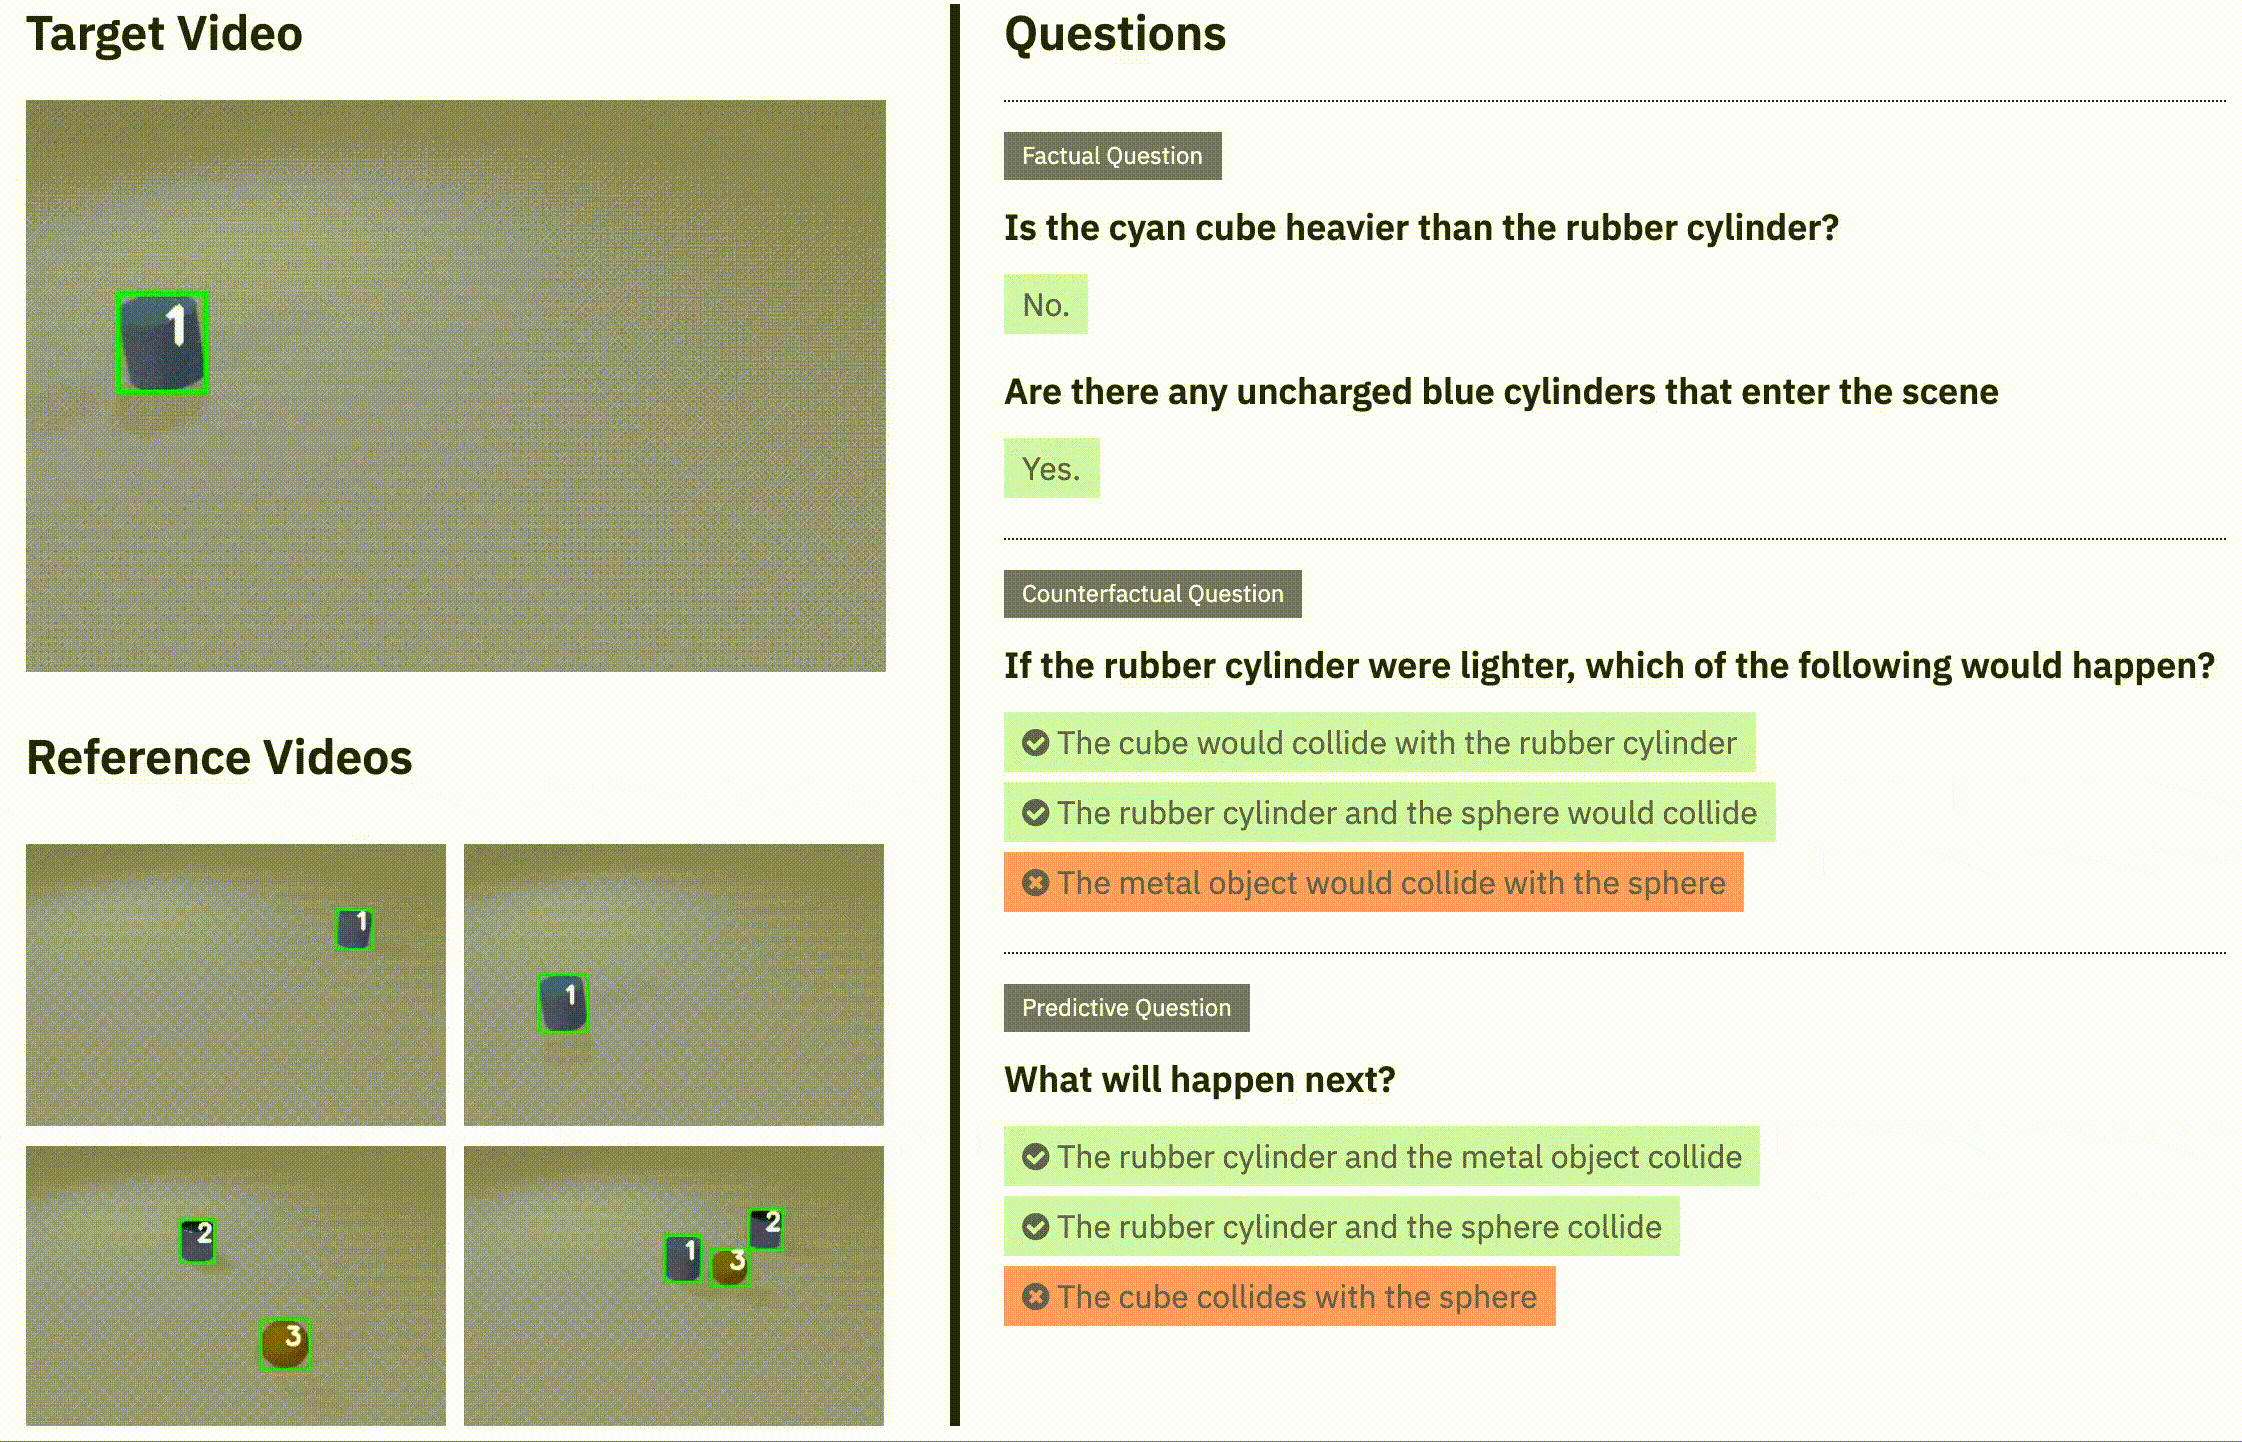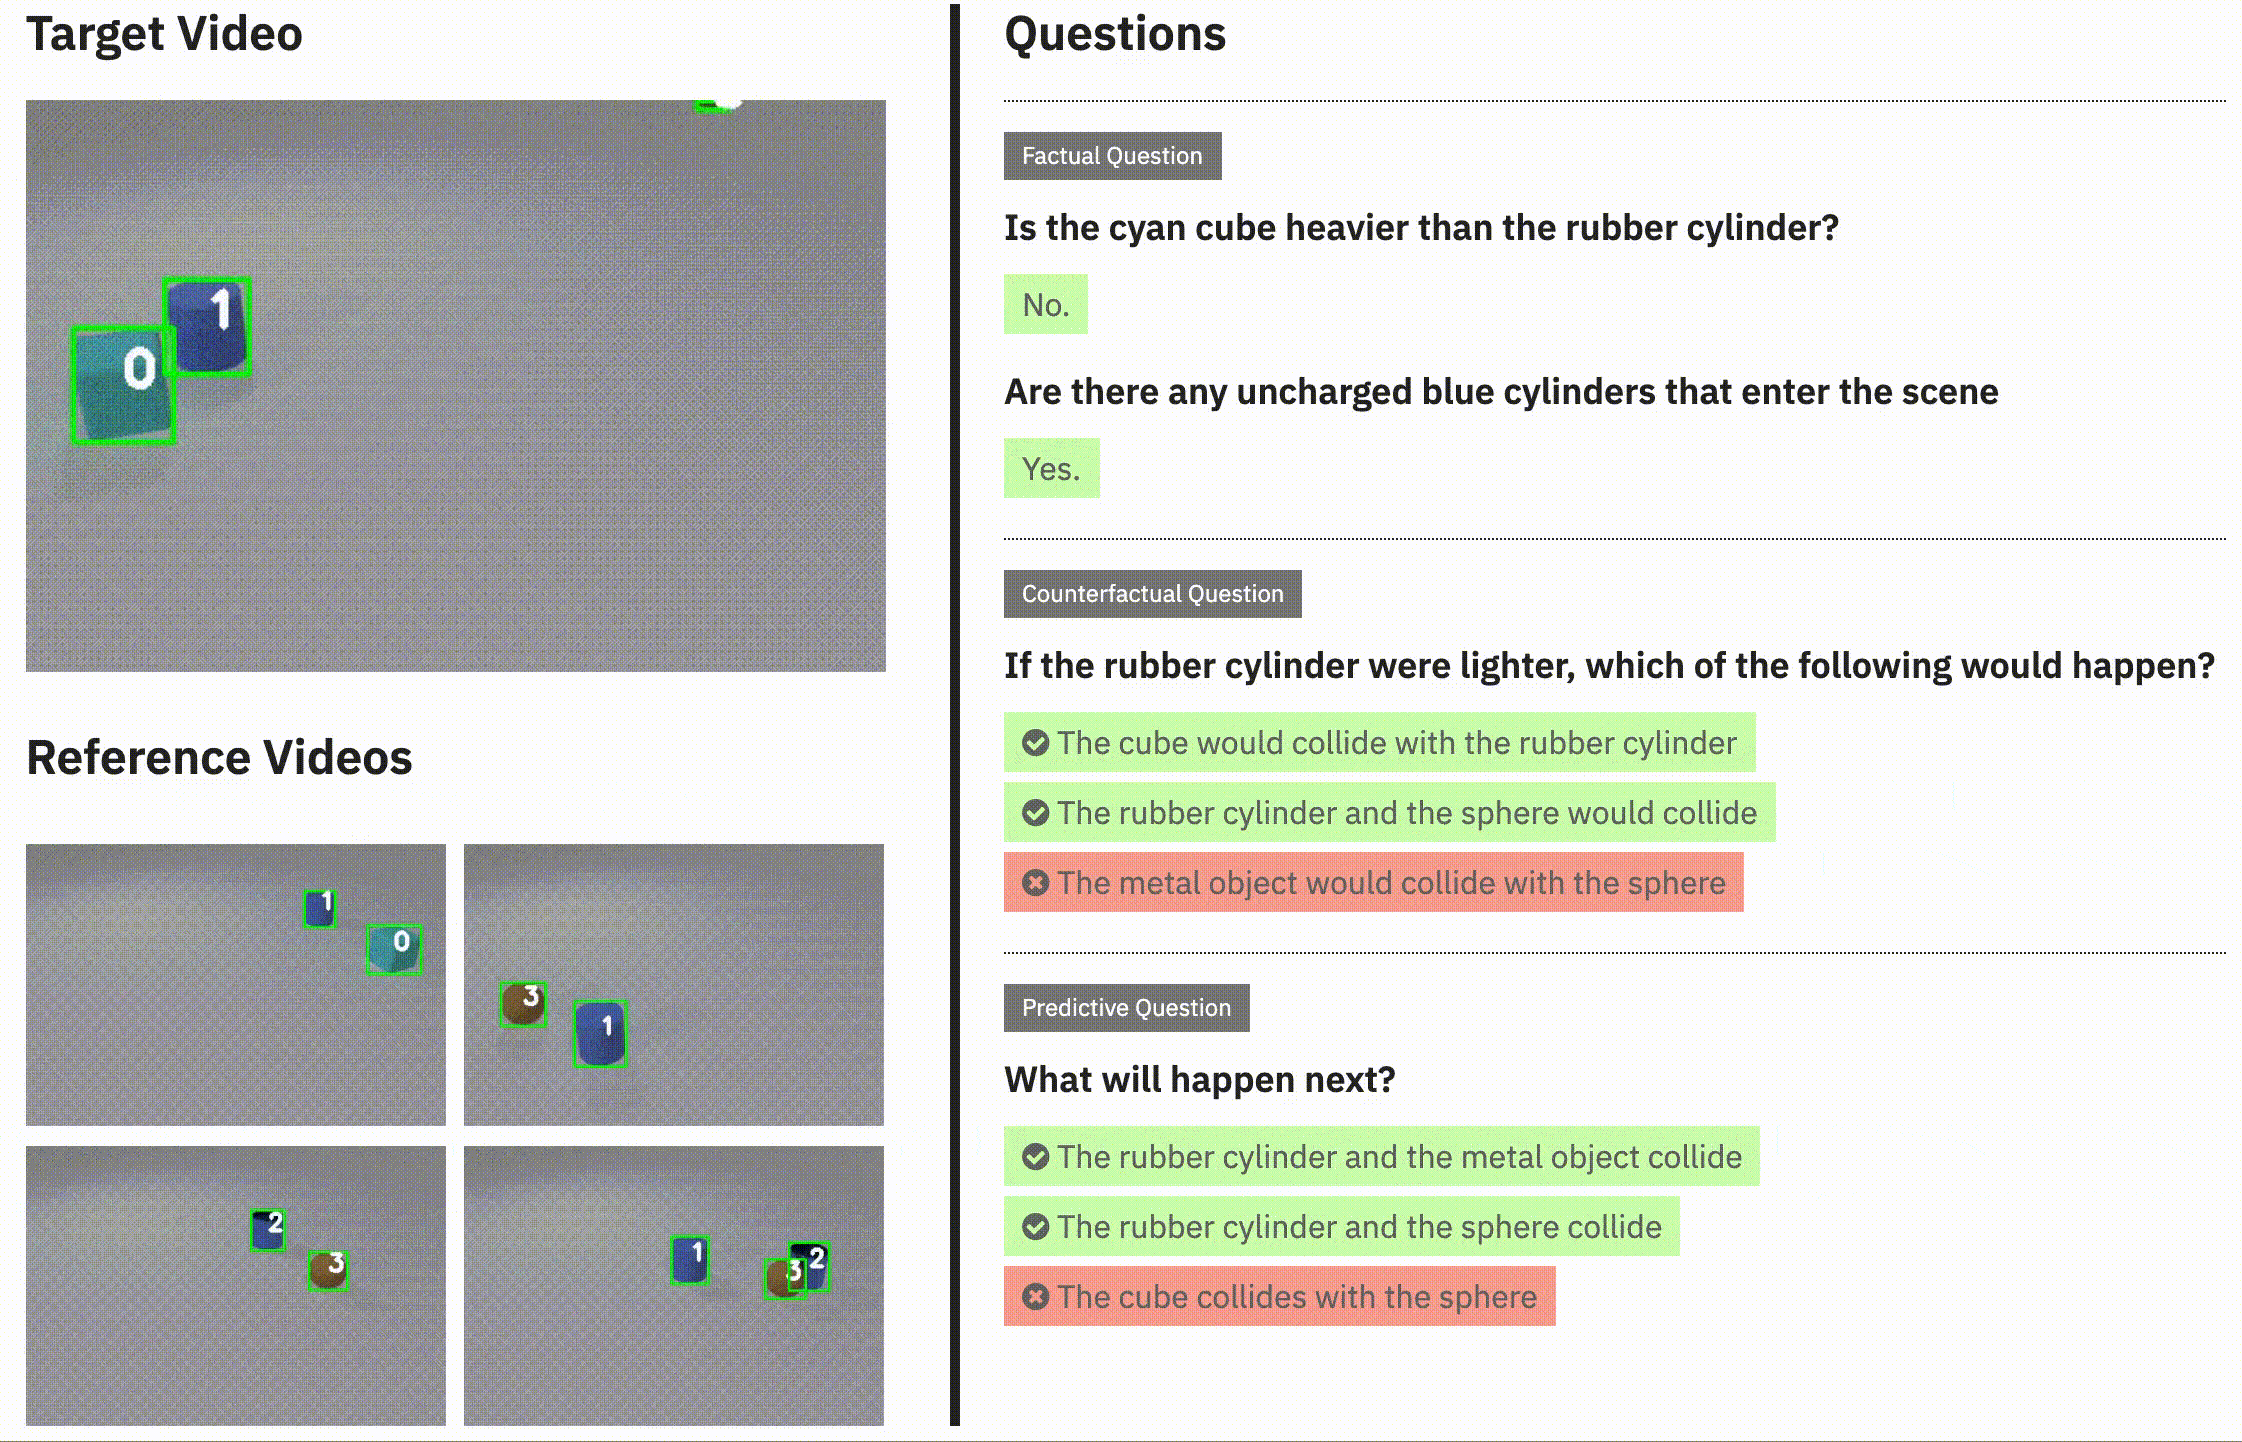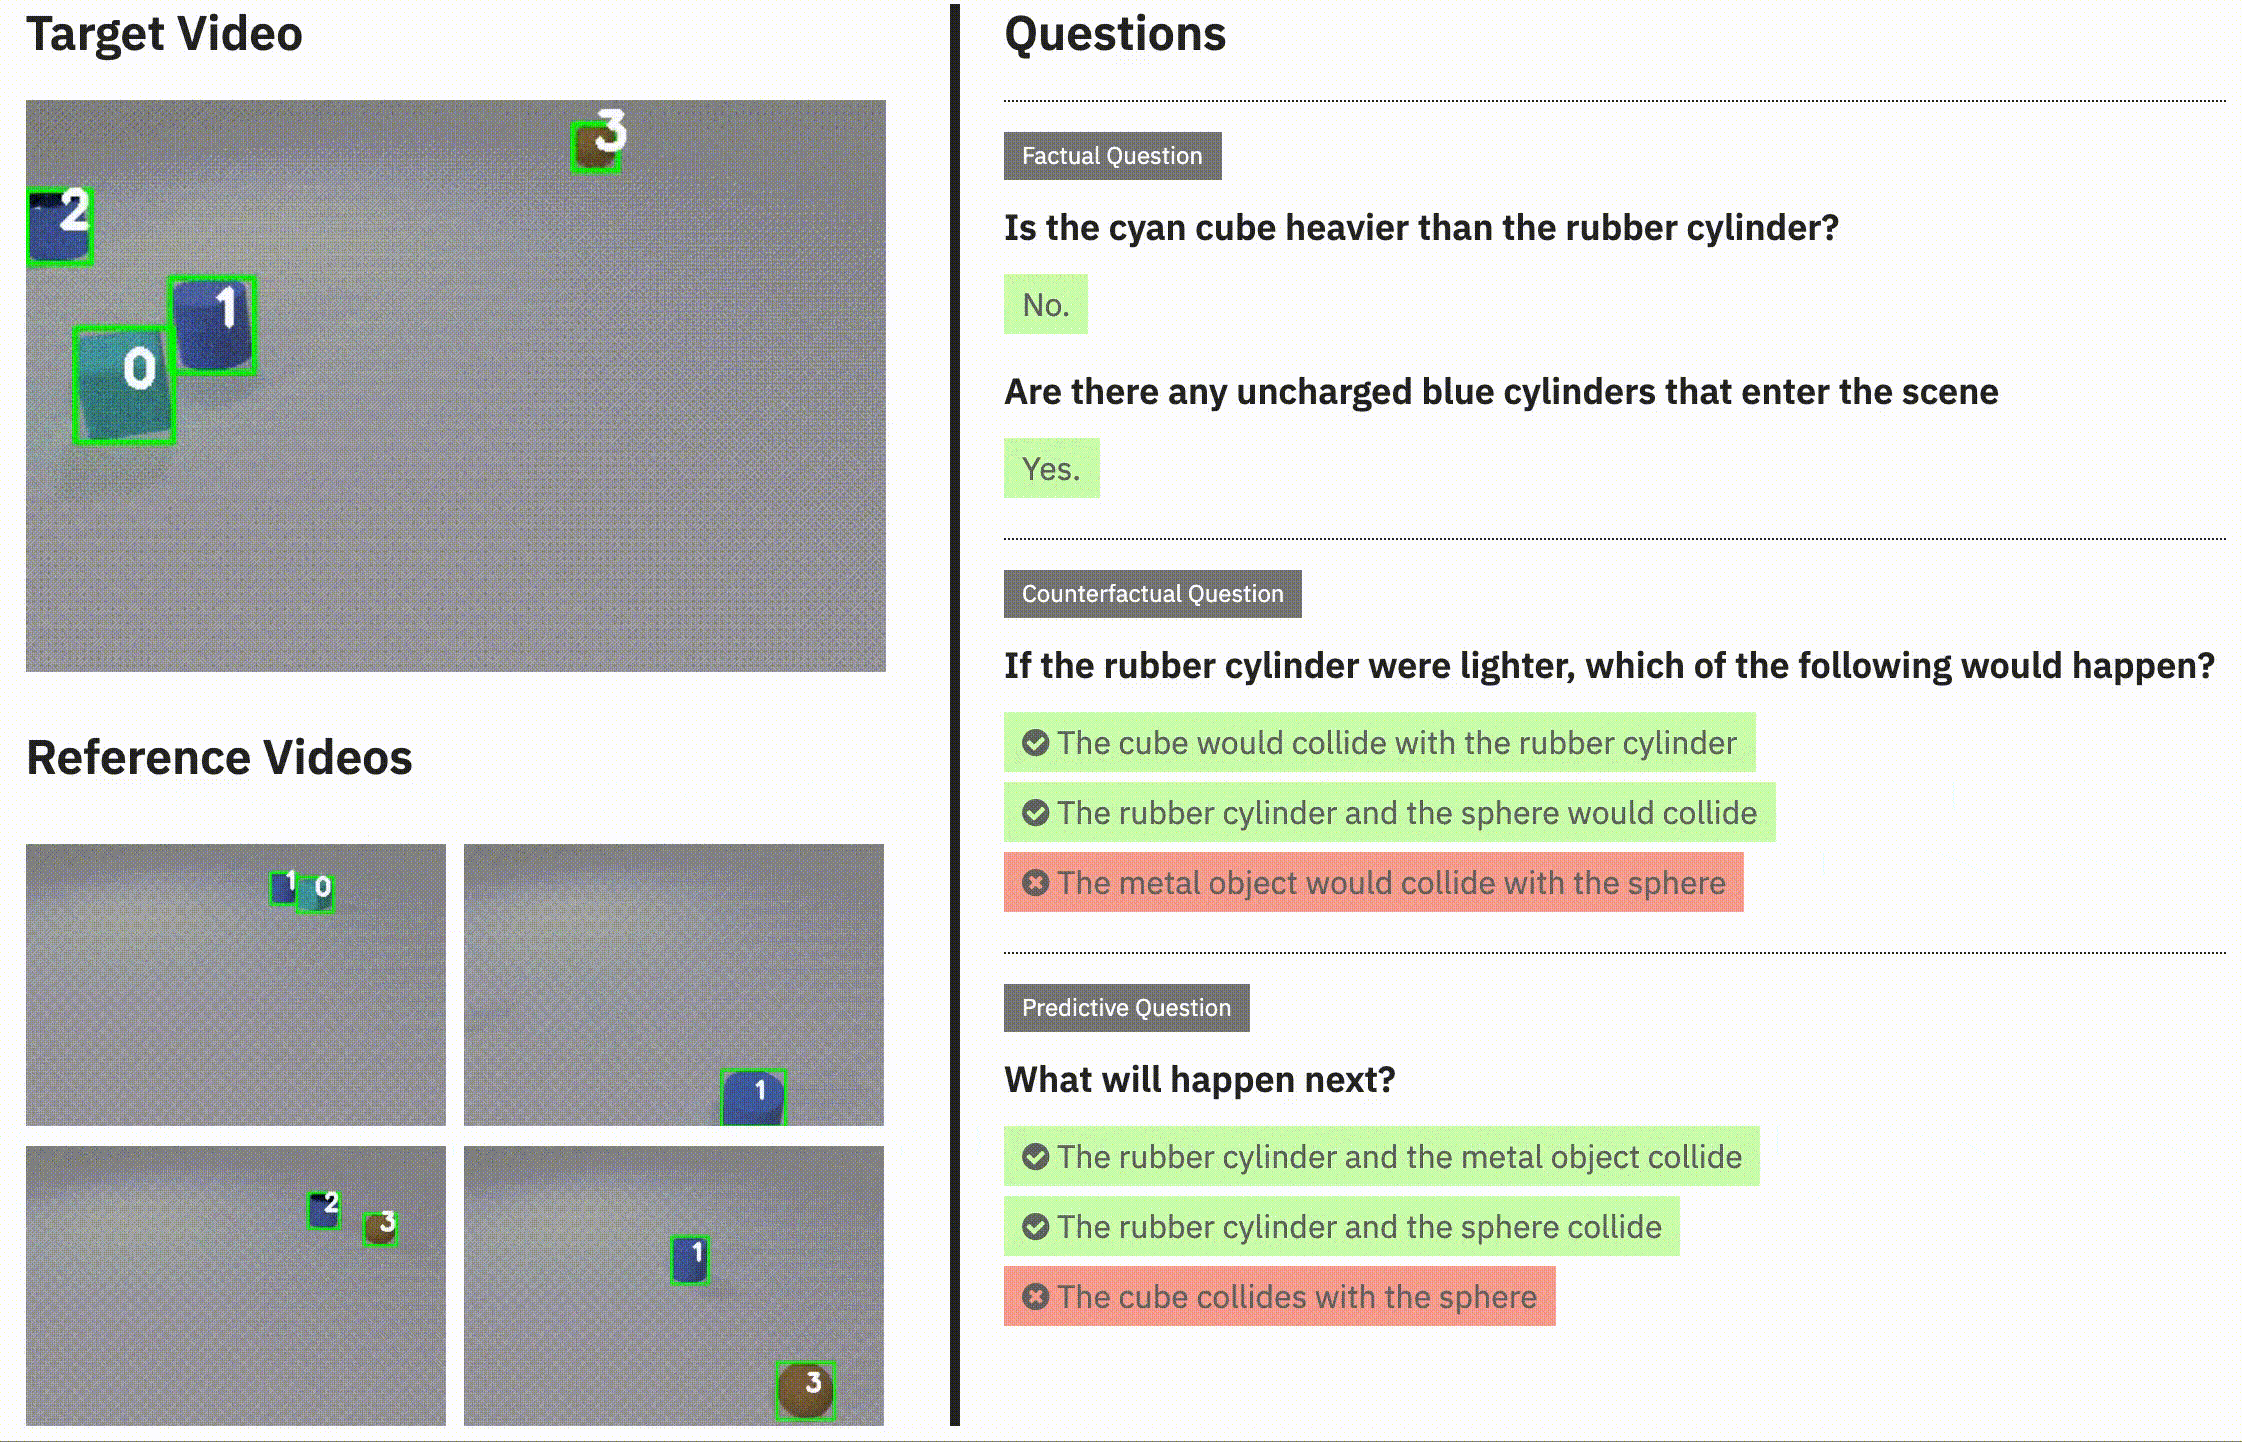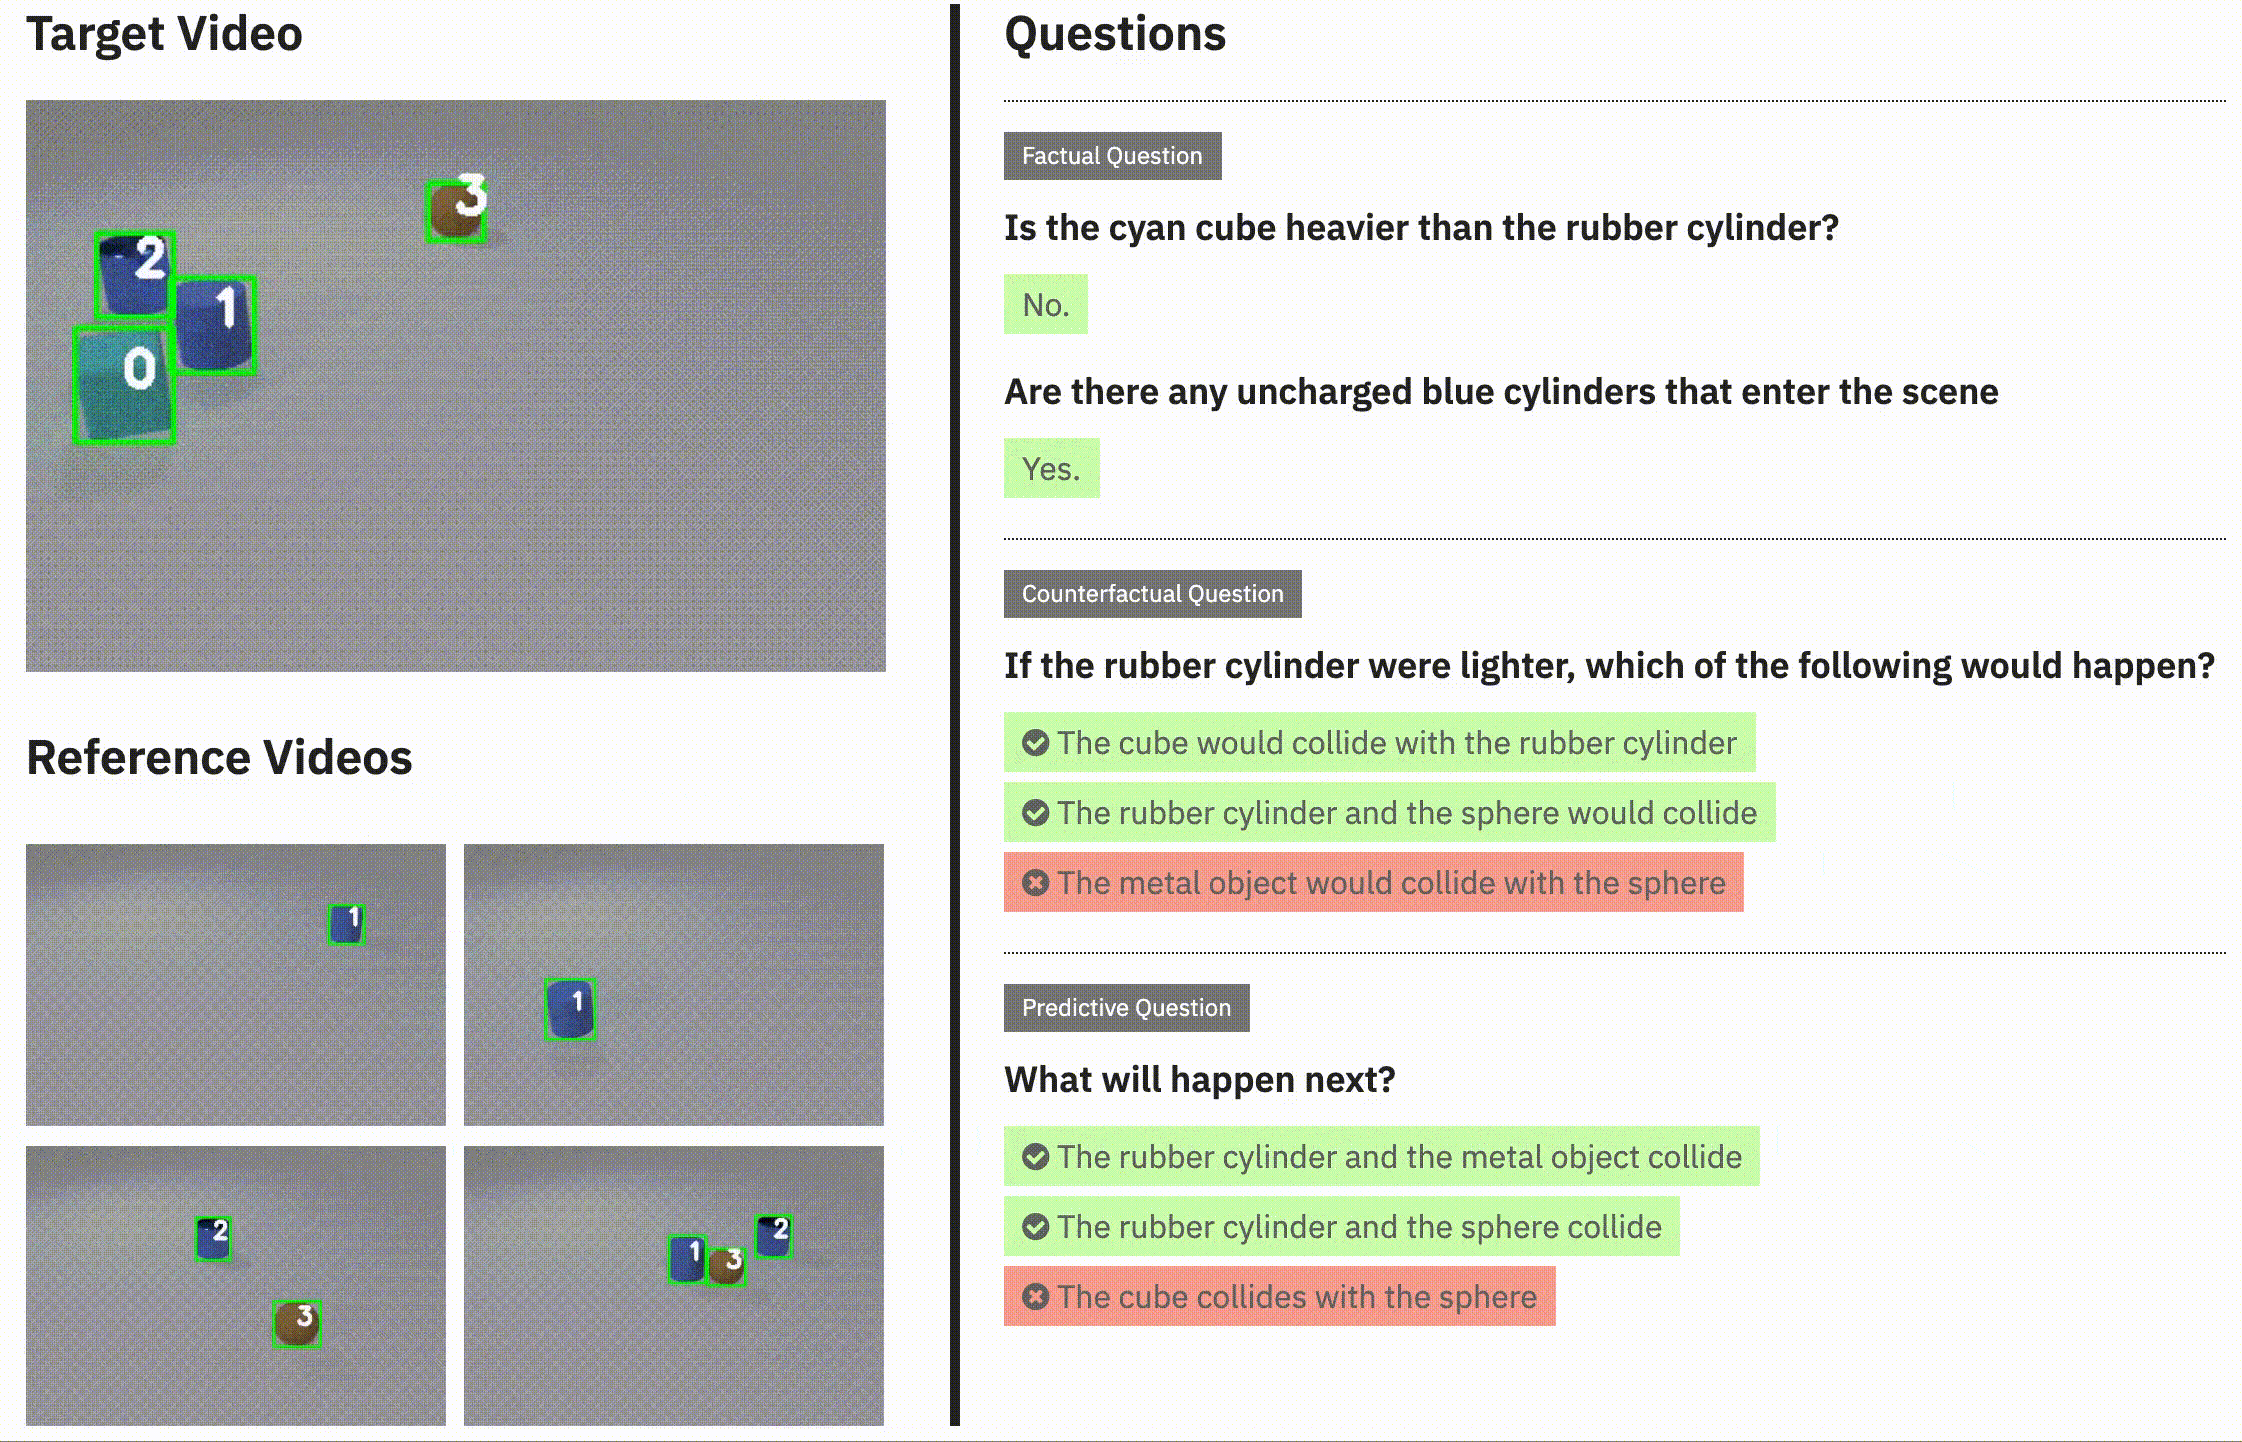
NeurIPS22: ComPhy Benchmark
-
Dexterous Manipulation: OHRA, DexH2R, CoorDex, UniDex, DexHandDiff, Current as Touch, DexCompose
-
Physics/Contact Modeling: GeoManip, Physics-aware Palletization, PhyGrasp, Object-Part Flow, VRDP, Physion++, ECL
-
World Models & VLAs: InterleaveVLA, CounterfactualVLA, LingBot-VA, Moto, GRAPE, ReBot, SkillDiffuser
-
Robotic Benchmarks: DexVerse, RoboTwin, RT-X, RoboDojo, EgoPlan-Bench, ComPhy, MMIE
-
Self-envolving Agents: RoboCodeX, AdaptDiffuser, AutoResearchClaw, SimpleMem, Agent0-VL, ReMAC, LanguageMPC
-
Foundational Models: EmbodiedGPT, Sparse Diffusion Policy, CAE, VDT, DaViT, Mod-Squad, VER
- Handroid: Bridging Dexterous Hand and Humanoid
- Ruogu Li, Chenyang Ma, Sikai Li, Zhenyu Wei, Yunchao Yao, Haochen Shi, C Karen Liu, Shuran Song, Mingyu Ding
- DenseReward: Dense Reward Learning via Failure Synthesis for Robotic Manipulation
- Yu Fang, Wanxi Dong, Jiaqi Liu, Yue Yang, Mingxiao Huo, Yao Mu, Huaxiu Yao, Li Erran Li, Daniel Szafir, Mingyu Ding
- DexVerse: A Modular Benchmark for Multi-Task, Multi-Embodiment Dexterous Manipulation
- Yunchao Yao, Zhuxiu Xu, Tianqi Zhang, …, Shuqi Zhao, Shenghua Gao, Masayoshi Tomizuka, Yi Ma, Mingyu Ding
- RoboDojo: A Unified Sim-and-Real Benchmark for Comprehensive Evaluation of Generalist Robot Manipulation Policies
- Tianxing Chen, Yue Chen, Zixuan Li, …, Wojciech Matusik, Mingyu Ding, Wenbo Ding, Ping Luo, Masayoshi Tomizuka
- Current as Touch: Proprioceptive Contact Feedback for Compliant Dexterous Manipulation
- Chenyang Ma, Yunchao Yao, Zhenyu Wei, Ruogu Li, Daniel Szafir, Mingyu Ding
- AnyBody: Free-Form Whole-Body Humanoid Control from Arbitrary Keypoint Guidance
- Shuning Li, Sikai Li, Jiachen Li, Mingyu Ding
- DexCompose: Reusing Dexterous Policies for Multi-Task Manipulation with a Single Hand
- Dihong Huang, Zhenyu Wei, Zhuxiu Xu, Yunchao Yao, Sikai Li, Mingyu Ding
- WatchAct: A Benwchmark for Behavior-Grounded Robot Manipulation
- Baiqi Li, Ce Zhang, Yu Fang, Yue Yang, Shangzhe Li, Mingyu Ding, Gedas Bertasius
- Learning Action Priors for Cross-embodiment Robot Manipulation
- Dong Jing, Tianqi Zhang, Jiaqi Liu, Jinman Zhao, Zelong Sun, Li Erran Li, Zhiwu Lu, Mingyu Ding
- CoorDex: Coordinating Body and Hand Priors for Continuous Dexterous Humanoid Loco-Manipulation
- Sikai Li, Shuning Li, Zhenyu Wei, Yunchao Yao, Chenran Li, Mingyu Ding
-
- Best Paper Award in Automation at ICRA 2025
-
2026 FallZixian Liu (B.S. in CS, Tsinghua Univ., Yao Class)
- Golden in 2020 Chinese Physics Olympiad Final
-
2025 FallSikai Li (B.S. in CS, UMich-SJTU)
-
- Best Paper Award in Robot Manipulation and Locomotion at ICRA 2025
-
-
2025 FallJiaqi Liu (B.S. in Transportation Engineering, Tongji Univ., ranked 1/163; co-advised with Huaxiu Yao)
-
2024 FallYu Fang (M.S. in CS, ShanghaiTech; co-advised with Daniel Szafir)
-
2024 FallChenyang Ma (M.S. in EE, Ohio State; co-advised with Daniel Szafir)
Selected Awards
- 2026 AAAI Faculty Highlight
- 2025 Amazon Research Award
- 2025 ICRA Best Paper Award in Automation (10/4,250)
- 2024 ICRA Best Paper Award (2/3,937)
- 2023 ME Rising Stars, UC Berkeley
- 2022 WAIC Rising Stars
- 2021 Baidu Fellowship
- 2018 Best Student Paper Runner-up Award in 25th ICONIP (2/575)
Teachings
- COMP 790-192 Embodied and Agentic AI, UNC
- COMP 790-186 Robot Learning, UNC
- Guest Lecture on Robotics at Duke, TAMU, UPenn, USC
Activities
- Area Chair for RSS, CoRL, CVPR, ICCV, ECCV, NeurIPS, ICLR, AAAI; Session Chair for ICRA, CVPR, ICLR
- Associate Editor for RA-L, IROS; Editorial Board Member of Humanoids; Section Board Member of Machines
- Guest Editor for Robotics - Embodied Intelligence; Pattern Recognition - Spatial Embodied Intelligence